paper_study/20260924-123303_60hz_hum_s1_report.md · raw markdown
GarageFly run report: 20260924-123303_60hz_hum_s1
Generated 2026-09-24T12:38:28 · condition 60hz_hum · seed 1 · 30 s simulated (323 s wall)
Setup
- Stimulus: 60 Hz mains hum with harmonics, loudness-matched
- Audio source:
synthetic:hum:{'freq': 60.0} - Playback level: 85 dB SPL RMS at 1 m (track_rms); ambient noise 30 dB SPL
- Speaker distance from start position: 355 mm
- Baseline (silent) period: 0–10.0 s; stimulus period: 10.0–30.0 s
- Brain: sensory-motor mode, 52,547 neurons, 5,540,690 connections (FlyWire v783)
- Software: Python 3.12.13, PyTorch 2.14.0+cu130, MuJoCo 3.9.0, GPU NVIDIA GeForce RTX 3090
Key observations (this run)
Physics QA: passed (no jumps > 1 mm per 10 ms; thorax height stayed 0.5–2.5 mm above the surface; max step 0.80 mm).
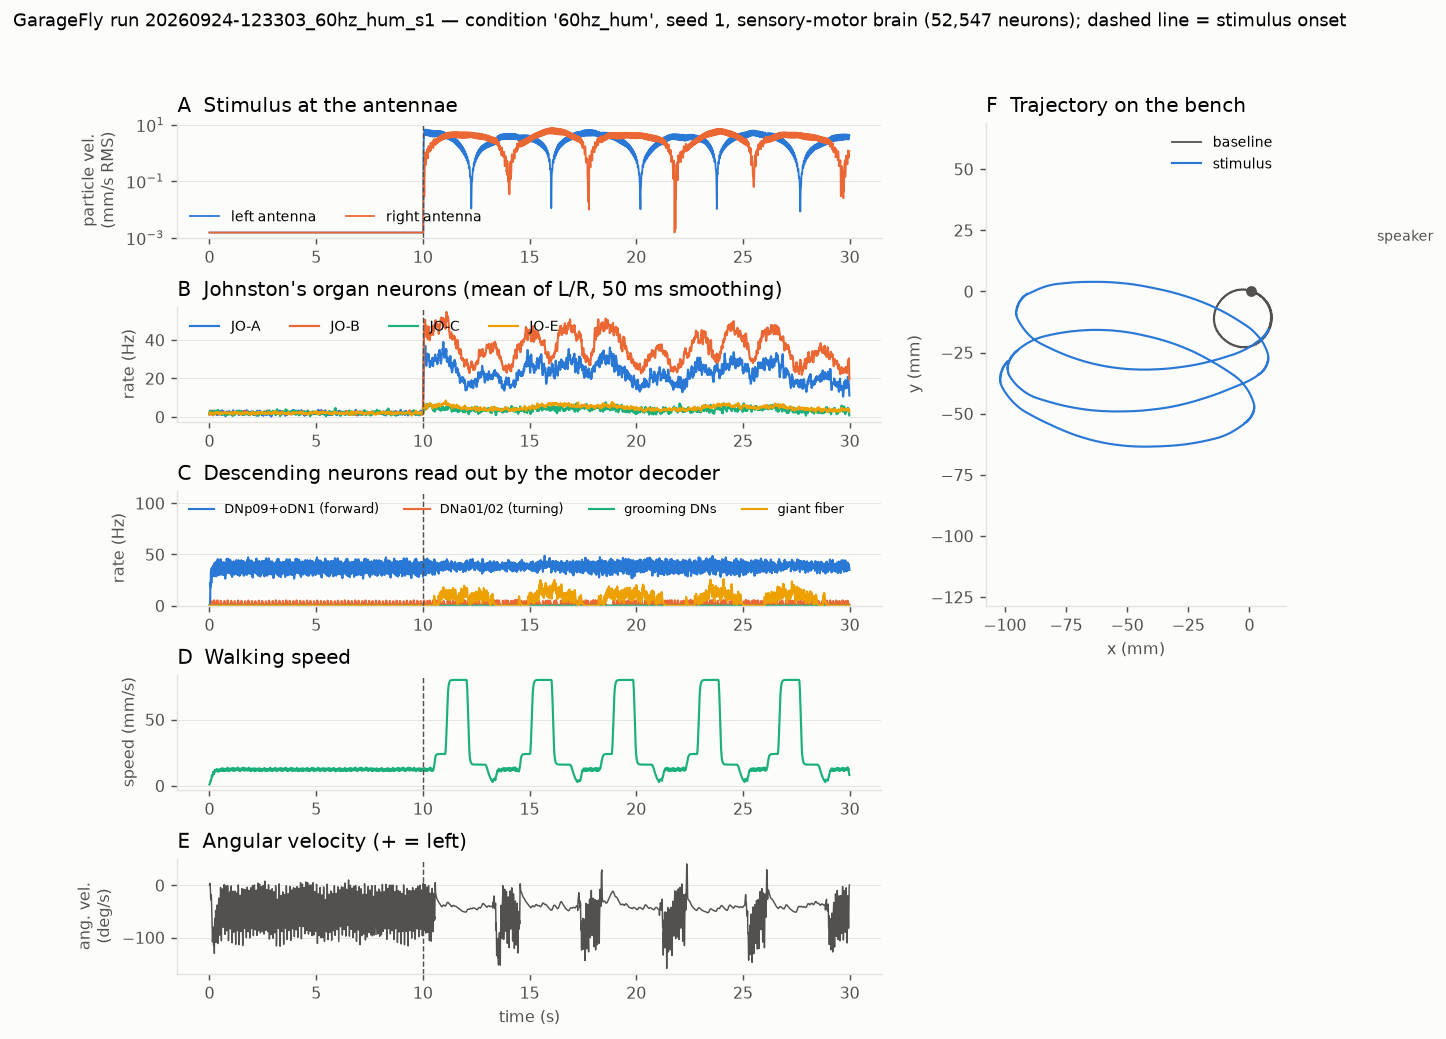
- Auditory Johnston's-organ neurons (JO-A/B, mean of both sides) fired at 29.7 Hz during the stimulus vs 2.0 Hz at baseline.
- Wind/gravity-sensitive JO-C/E neurons: 4.4 Hz vs 2.0 Hz.
- Mean walking speed was 11.21 mm/s during the stimulus vs 11.98 mm/s at baseline (-6%).
- Turning bias: -45.9 deg/s vs -47.2 deg/s (+ = leftward); freezing fraction 0.00 vs 0.00.
- Giant-fiber (escape) DN rate: 6.1 Hz vs 0.0 Hz; 5 escape-command episodes during the stimulus (0 at baseline). Each can trigger a takeoff unless the fly is already airborne or within the post-landing refractory period.
- Behaviour: walking 30%, grooming 0.0%, flight 70% of the stimulus period (15.0 takeoffs/min, 0.0 grooming bouts/min) vs walking 100%, grooming 0.0%, flight 0% at baseline.
A single run is one stochastic sample. Differences between baseline and stimulus within a run, or between single runs, are not statistically established. Use
scripts/compare_conditions.pyover several seeds per condition for inferential statistics.
Behaviour
| Measure | Baseline | Stimulus | Change |
|---|---|---|---|
| Fraction of time walking | 1.00 | 0.30 | -0.70 |
| Fraction of time grooming (body) | 0.00 | 0.00 | 0.00 |
| Fraction of time in flight | 0.00 | 0.70 | 0.70 |
| Takeoffs per minute | 0.00 | 15.00 | 15.00 |
| Grooming bouts per minute | 0.00 | 0.00 | 0.00 |
| Righting events (fell over) | 0.00 | 0.00 | 0.00 |
| Mean walking speed while walking (mm/s) | 11.98 | 11.21 | -0.76 |
| Distance travelled (mm) | 119.81 | 617.46 | 497.65 |
| Fraction of time freezing | 0.00 | 0.00 | 0.00 |
| Mean | angular velocity | (deg/s) | 47.33 |
| Turning bias (deg/s, + = left) | -47.16 | -45.88 | 1.28 |
| Fraction of time grooming command active | 0.00 | 0.00 | 0.00 |
| Escape (giant fiber) command episodes | 0.00 | 5.00 | 5.00 |
| Escape command episodes per minute | 0.00 | 15.00 | 15.00 |
| Fraction of time escape command active | 0.00 | 0.52 | 0.52 |
| Mean distance to speaker (mm) | 327.66 | 381.71 | 54.05 |
Neural activity: sensory input and descending output
| Neuron group | Baseline (Hz) | Stimulus (Hz) | Change (Hz) |
|---|---|---|---|
| JO-A (left) | 2.10 | 22.09 | 19.99 |
| JO-A (right) | 1.98 | 24.37 | 22.39 |
| JO-B (left) | 2.06 | 34.55 | 32.49 |
| JO-B (right) | 1.99 | 37.64 | 35.65 |
| JO-C (left) | 2.06 | 4.16 | 2.11 |
| JO-C (right) | 1.98 | 3.66 | 1.68 |
| JO-D (left) | 1.93 | 8.77 | 6.84 |
| JO-D (right) | 2.00 | 13.21 | 11.21 |
| JO-E (left) | 2.00 | 4.50 | 2.50 |
| JO-E (right) | 1.98 | 5.26 | 3.28 |
| JO-F (left) | 2.03 | 2.02 | -0.01 |
| JO-F (right) | 2.02 | 1.96 | -0.06 |
| DNp09 (left) | 30.78 | 30.84 | 0.06 |
| DNp09 (right) | 30.78 | 30.95 | 0.17 |
| oDN1 (left) | 46.18 | 49.08 | 2.90 |
| oDN1 (right) | 39.97 | 42.72 | 2.75 |
| DNa01 (left) | 0.00 | 0.00 | 0.00 |
| DNa01 (right) | 0.00 | 0.00 | 0.00 |
| DNa02 (left) | 0.00 | 0.00 | 0.00 |
| DNa02 (right) | 6.20 | 7.58 | 1.38 |
| MDN (left) | 0.00 | 0.00 | 0.00 |
| MDN (right) | 0.00 | 0.00 | 0.00 |
| aDN2 (left) | 0.00 | 0.00 | 0.00 |
| aDN2 (right) | 0.00 | 0.00 | 0.00 |
| DNg11 (left) | 0.00 | 0.00 | 0.00 |
| DNg11 (right) | 0.00 | 0.00 | 0.00 |
| DNg12 (left) | 0.00 | 0.00 | 0.00 |
| DNg12 (right) | 0.00 | 0.00 | 0.00 |
| GF (left) | 0.00 | 0.00 | 0.00 |
| GF (right) | 0.00 | 12.26 | 12.26 |
| MN9 (left) | 0.00 | 0.00 | 0.00 |
| MN9 (right) | 0.00 | 0.00 | 0.00 |
Neural activity by FlyWire super-class (mean rate per neuron)
| Super-class | Baseline (Hz) | Stimulus (Hz) |
|---|---|---|
| ascending | 0.0000 | 0.0003 |
| central | 0.0003 | 0.0147 |
| descending | 0.1619 | 0.3647 |
| endocrine | 0.0000 | 0.0000 |
| motor | 0.0564 | 0.0918 |
| sensory | 0.1283 | 0.8905 |
| sensory_ascending | 0.0000 | 0.0000 |
| unannotated | 0.0000 | 0.0000 |
Most responsive cell types (largest |change| stimulus − baseline)
| cell_type | super_class | n_neurons | baseline_hz | stimulus_hz | delta_hz |
|---|---|---|---|---|---|
| JO-B4_a | sensory | 15 | 1.81 | 42.10 | 40.29 |
| JO-B2 | sensory | 36 | 2.06 | 41.79 | 39.73 |
| JO-B1_b | sensory | 27 | 2.05 | 38.31 | 36.26 |
| JO-B3 | sensory | 29 | 2.09 | 37.80 | 35.71 |
| JO-B1_c | sensory | 22 | 2.14 | 34.70 | 32.56 |
| JO-B1_a | sensory | 105 | 2.04 | 33.48 | 31.44 |
| JO-A3 | sensory | 6 | 2.13 | 29.38 | 27.24 |
| JO-B4_b | sensory | 25 | 1.90 | 28.86 | 26.97 |
| JO-A5 | sensory | 37 | 1.95 | 26.61 | 24.66 |
| CB3876 | central | 1 | 0.00 | 23.65 | 23.65 |
| DNg29 | descending | 2 | 0.00 | 23.05 | 23.05 |
| CB0478 | central | 2 | 0.05 | 21.00 | 20.95 |
| DNb06 | descending | 2 | 0.05 | 20.88 | 20.82 |
| JO-A2 | sensory | 33 | 2.21 | 22.86 | 20.65 |
| JO-A4 | sensory | 2 | 1.90 | 18.75 | 16.85 |
Most responsive downstream (non-sensory) cell types
| cell_type | super_class | n_neurons | baseline_hz | stimulus_hz | delta_hz |
|---|---|---|---|---|---|
| CB3876 | central | 1 | 0.00 | 23.65 | 23.65 |
| DNg29 | descending | 2 | 0.00 | 23.05 | 23.05 |
| CB0478 | central | 2 | 0.05 | 21.00 | 20.95 |
| DNb06 | descending | 2 | 0.05 | 20.88 | 20.82 |
| CB0466 | central | 2 | 0.00 | 13.78 | 13.78 |
| CB0033 | central | 2 | 0.00 | 12.03 | 12.03 |
| DNp12 | descending | 2 | 0.00 | 10.82 | 10.82 |
| CB3911 | central | 1 | 0.00 | 10.05 | 10.05 |
| CB3716 | central | 2 | 0.00 | 9.20 | 9.20 |
| DNp73 | descending | 2 | 0.00 | 9.15 | 9.15 |
| CB2556 | central | 7 | 0.00 | 8.38 | 8.38 |
| SAD053 | central | 2 | 0.00 | 8.07 | 8.07 |
| CB1038b | central | 2 | 0.00 | 6.92 | 6.92 |
| DNp40 | descending | 2 | 0.00 | 6.92 | 6.92 |
| DNpe014 | descending | 4 | 0.00 | 6.44 | 6.44 |
Methods paragraph (draft, auto-generated)
A connectome-constrained leaky integrate-and-fire model of the adult Drosophila brain (FlyWire FAFB v783; 52,547 neurons and 5,540,690 connections in 'sensory-motor' mode; neuron parameters from Shiu et al. 2024) was simulated on a GPU at a 0.1 ms time step, in closed loop with the NeuroMechFly v2 body (FlyGym 2.1, MuJoCo 3.9.0). Audio (60 Hz mains hum with harmonics, loudness-matched) was calibrated to 85 dB SPL (RMS) at 1 m (track_rms calibration) and played from a virtual point source 355 mm from the fly's start position. Air particle velocity at each antenna was computed in 20 log-spaced bands (15–1500 Hz), including the acoustic near field and a cosine directional sensitivity. It was converted into Poisson firing rates of the FlyWire-annotated Johnston's organ neurons (JO-A to JO-E) through a resonant antenna filter and subgroup-specific frequency weighting. Descending-neuron activity (DNp09/oDN1, DNa01/DNa02, MDN, aDN2/DNg11/DNg12, giant fiber) was decoded into a two-dimensional locomotor drive for FlyGym's CPG-based controller, a grooming command (executed with measured front-leg grooming kinematics from an aDN-activated fly; Lobato-Rios et al. 2022) and an escape command (triggering an engineered takeoff-and-flight behaviour with externally applied lift; no wing aerodynamics). The first 10 s of each 30 s run were silent (baseline). Random seed 1.
Interpretation limits
- JO transfer functions, playback level, decoder gains and the tonic walking bias are arbitrary parameters (provenance in the run's JSON metadata). Conclusions should be checked for robustness to them.
- The ventral nerve cord is not simulated. Walking is produced by an engineered CPG controller driven by a few descending neurons.
- No substrate (bench) vibration, room acoustics, active antennal amplification, neuromodulation or gap junctions are modelled.
- Grooming uses measured kinematics but has no antennal contact mechanics. Flight is an engineered abstraction (applied lift/thrust, attitude PD); its speed, altitude and duration are arbitrary.
- Full list:
docs/MODEL_LIMITATIONS.md.
Files
- Raw data:
20260924-123303_60hz_hum_s1.h5(HDF5; behaviour, neural group rates, all spikes, stimulus) - Metadata:
20260924-123303_60hz_hum_s1.json - Machine-readable summary:
20260924-123303_60hz_hum_s1_summary.json